ACTION 01

Picking

Lifting an object free of its surroundings so it can be moved or handled

Why It Matters

Picking underlies most manipulation tasks. Examples include products packed tightly side by side on retail shelves, commingled parcels in inbound totes, and parts seated tightly in trays on a production line.

Suction grippers work only on objects that are flat, rigid, and accessible from above. For everything else, a graspable surface must first be created through contact.

Skills 10

01-AThin Object Picking

Too thin at the edges for a fingertip to bear on and flush against its support underneath, the object offers no pair of opposing faces to grip.
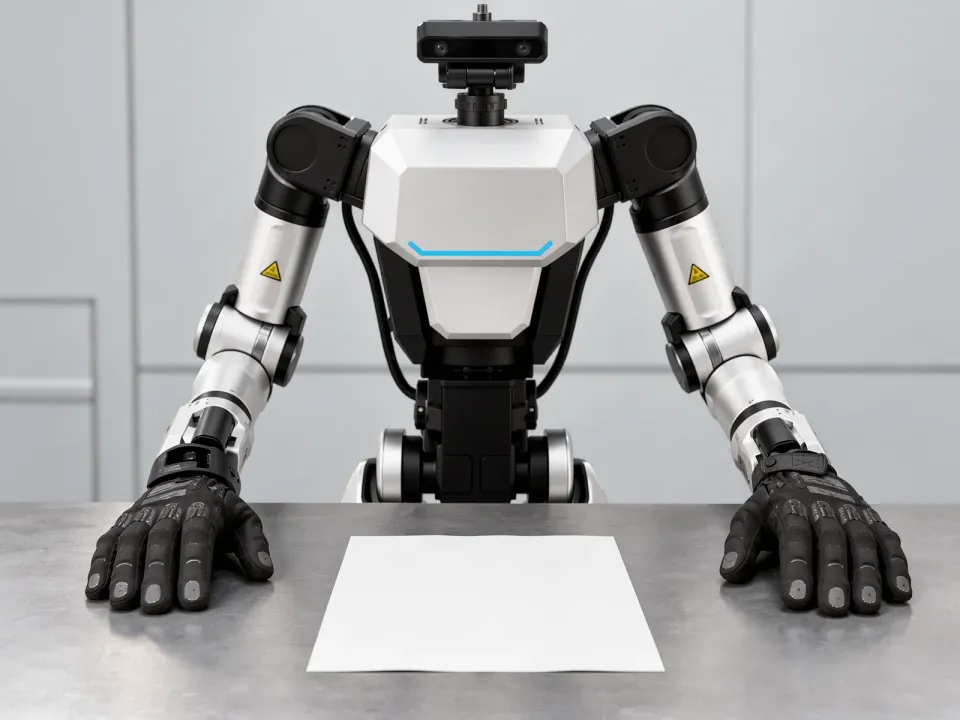
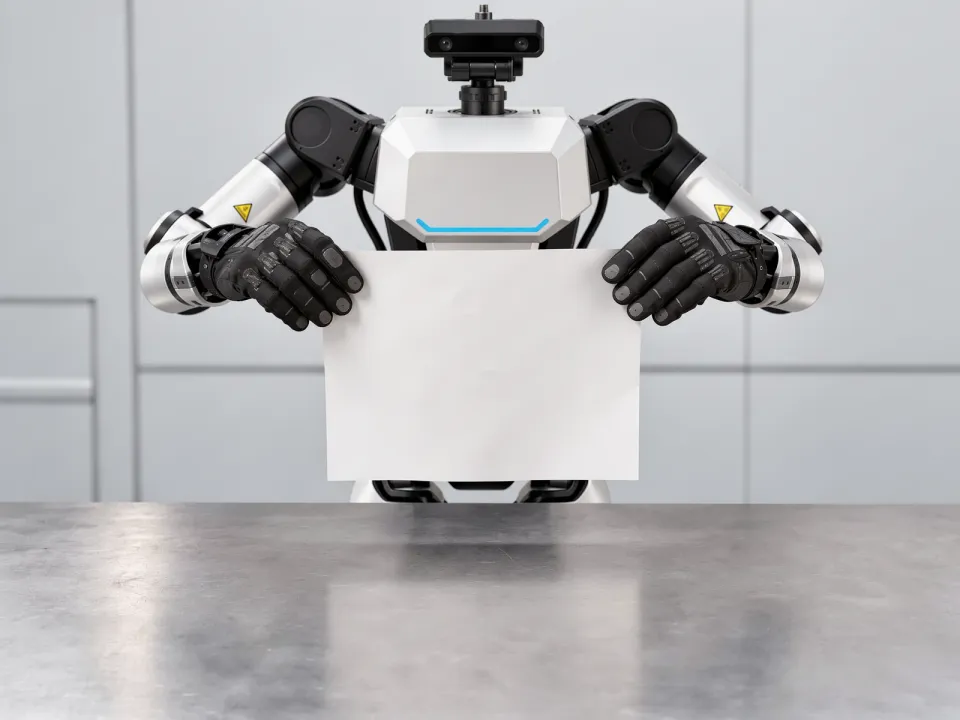
Thin Object Picking — Initial state
Initial stateAn object thinner than a fingertip lies flush against a support surface.
Thin Object Picking — Final state
Final stateThe object is grasped and lifted clear of the support surface.
C_geom appliesC_force appliesC_contact appliesC_obs appliesC_deform does not applyC_dyn does not apply
E1 appliesE2 does not applyE3 does not applyE4 appliesE5 does not apply

01-BCluttered Object Picking

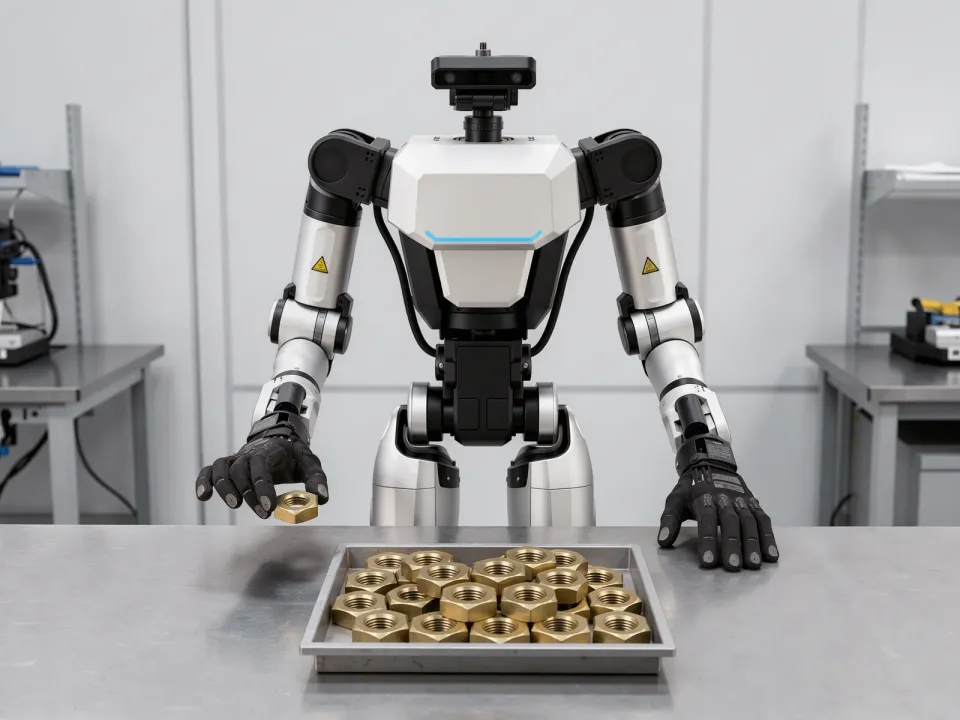
The target overlaps with other items, so grasping and withdrawing it alone drags its neighbors along.
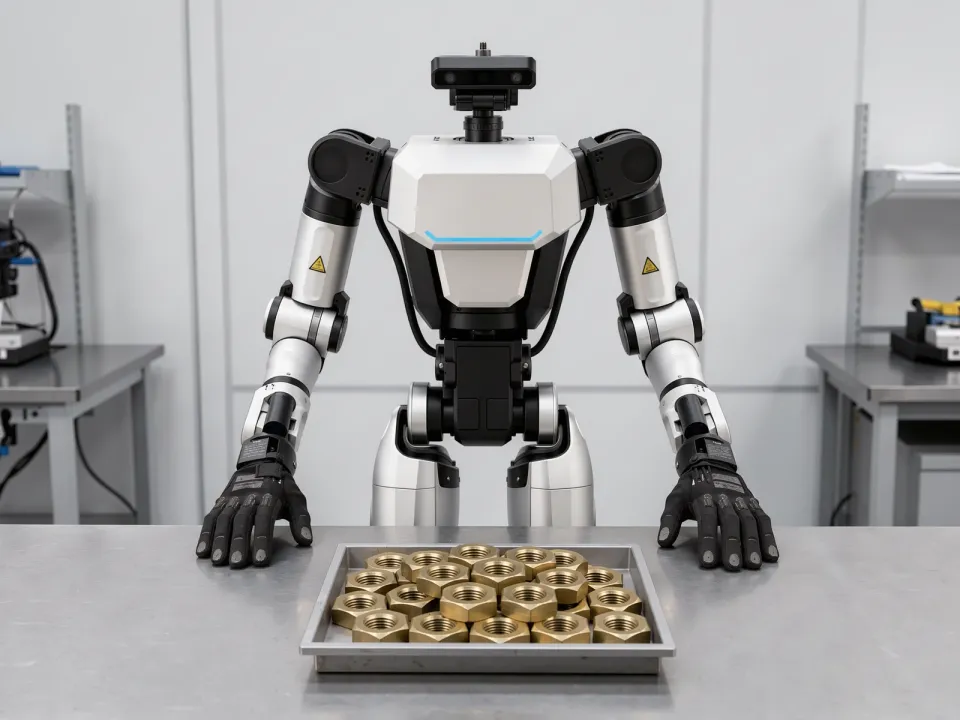
Cluttered Object Picking — Initial state
Initial stateObjects of the same kind are packed together in a container, overlapping one another.
Cluttered Object Picking — Final state
Final stateThe target object is grasped and withdrawn from the container.
C_geom appliesC_force does not applyC_contact appliesC_obs appliesC_deform does not applyC_dyn does not apply
E1 does not applyE2 appliesE3 does not applyE4 does not applyE5 applies

01-CTight-Fit Picking

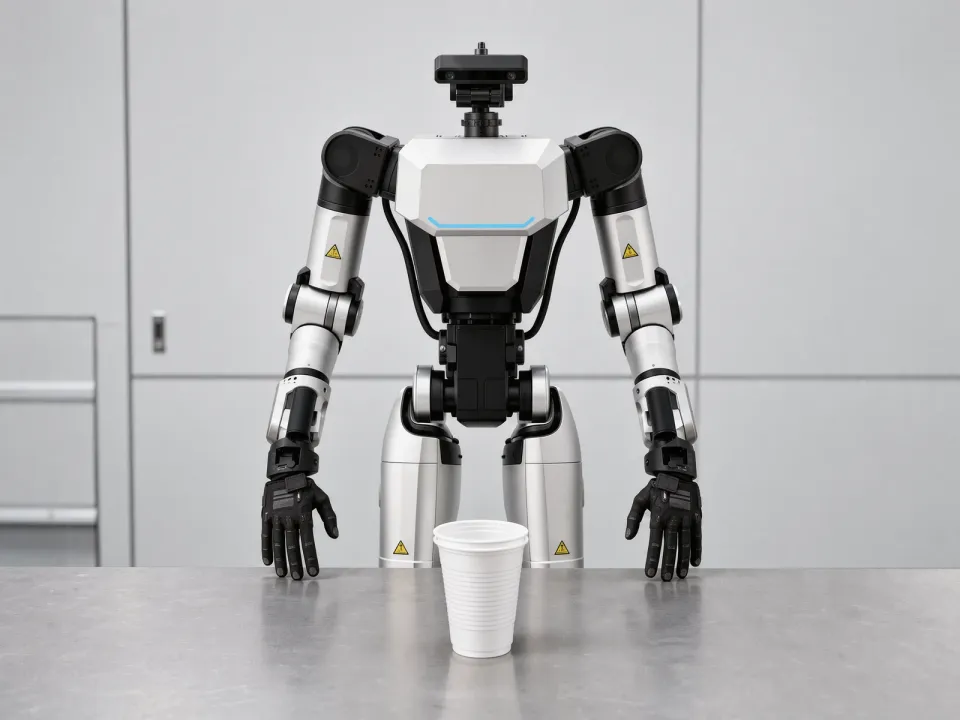
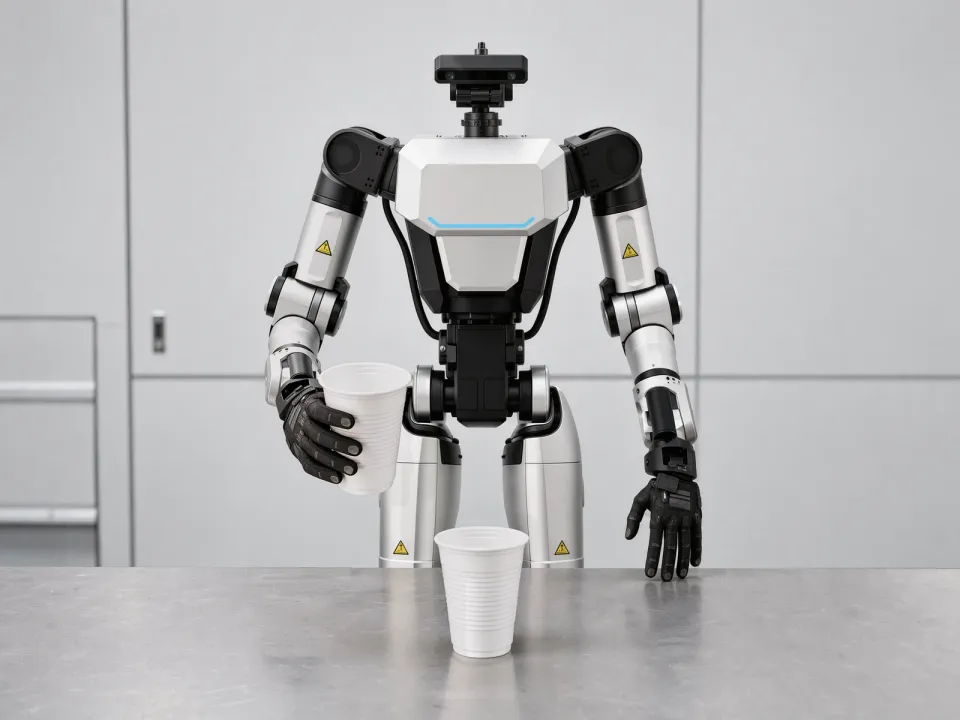
Held flush or by suction against its support, the object drags its surroundings with it on withdrawal, and the accumulated force is released all at once when the bond breaks.
Tight-Fit Picking — Initial state
Initial stateAn object is pressed flush against its support or attached to it by suction.
Tight-Fit Picking — Final state
Final stateOnly the object is separated from its support and grasped.
C_geom does not applyC_force appliesC_contact appliesC_obs appliesC_deform does not applyC_dyn applies
E1 appliesE2 does not applyE3 appliesE4 appliesE5 does not apply

01-DConstrained-Space Picking

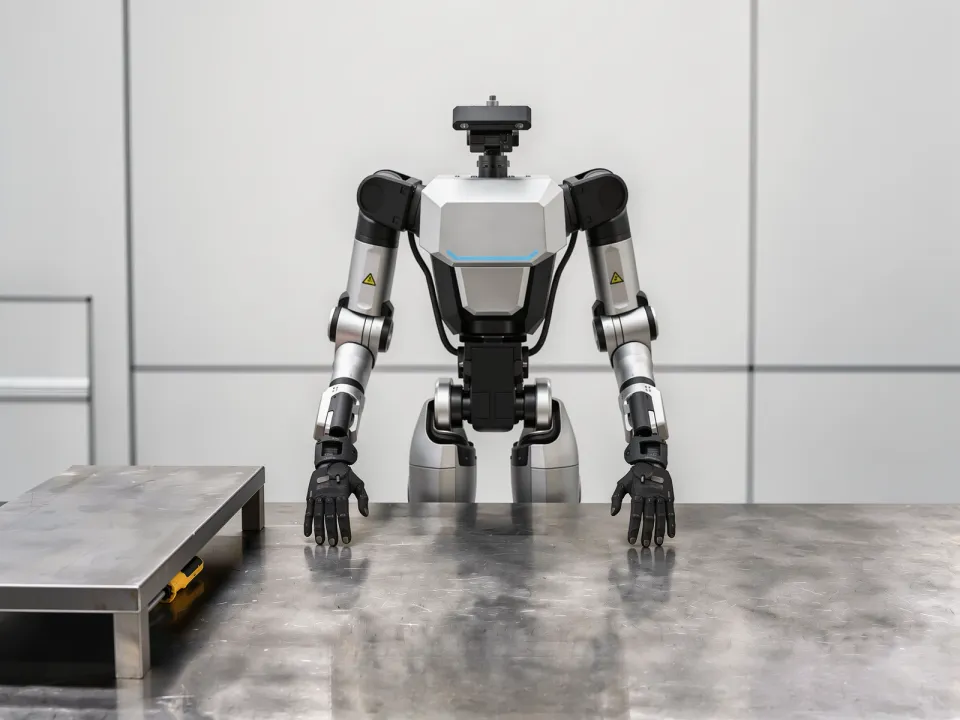
Surrounding structures constrain both the arm's path and the hand's shape, leaving only the grasps the space allows rather than the one the object calls for.
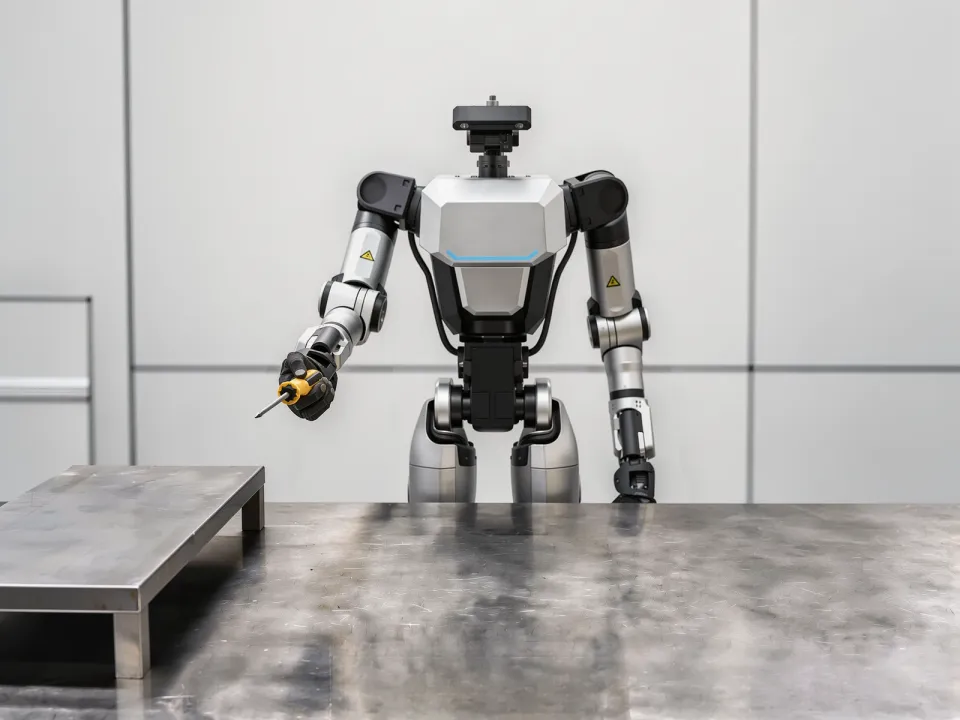
Constrained-Space Picking — Initial state
Initial stateAn object sits inside a space whose surrounding structures limit the approach direction.
Constrained-Space Picking — Final state
Final stateThe object is grasped and withdrawn from the confined space.
C_geom appliesC_force does not applyC_contact does not applyC_obs appliesC_deform does not applyC_dyn does not apply
E1 appliesE2 appliesE3 does not applyE4 does not applyE5 does not apply

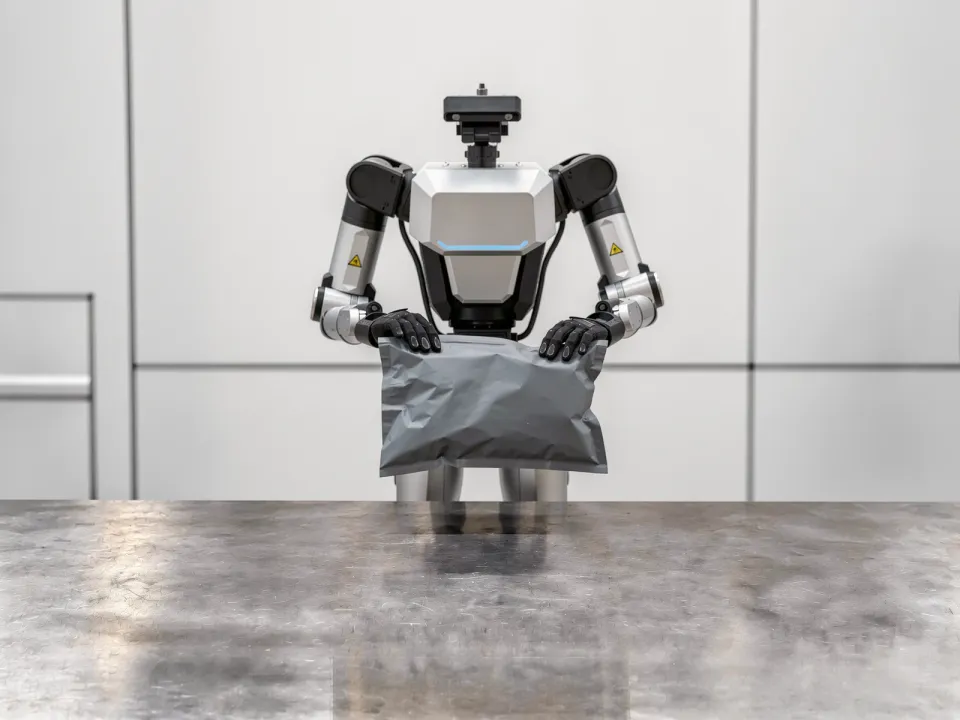
01-EDeformable Object Picking

The slightest force changes both the object's shape and its grasp points, so a grasp planned before contact no longer fits once contact is made.
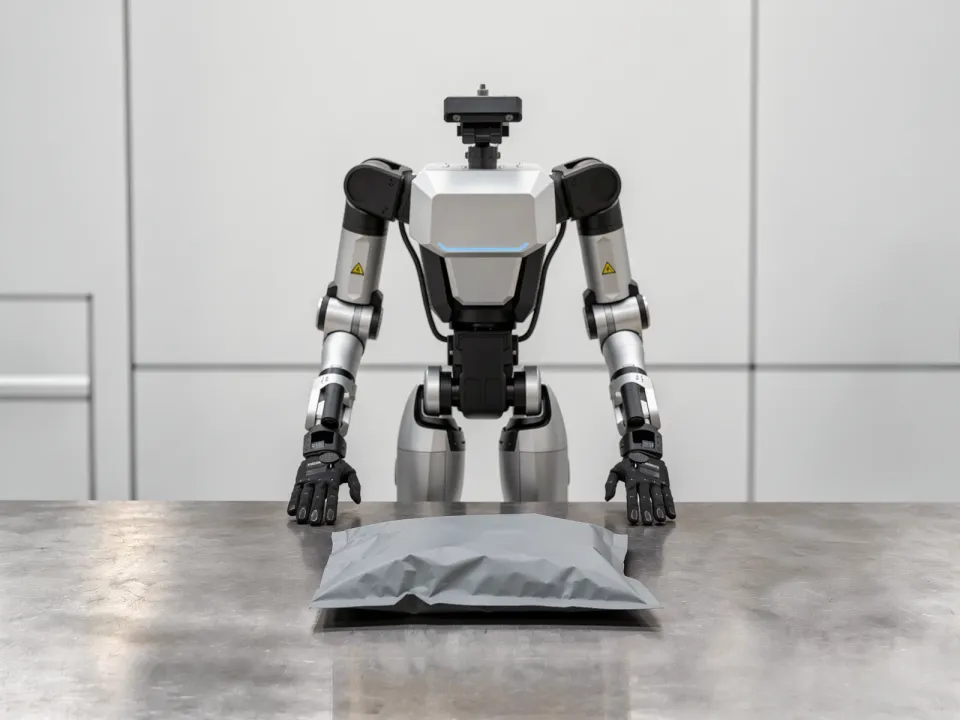
Deformable Object Picking — Initial state
Initial stateAn object whose shape changes on contact rests on a support surface.
Deformable Object Picking — Final state
Final stateThe object is grasped and lifted into the air.
C_geom does not applyC_force appliesC_contact appliesC_obs does not applyC_deform appliesC_dyn does not apply
E1 appliesE2 does not applyE3 does not applyE4 appliesE5 does not apply

01-FSoft Object Picking

Stiffness is not revealed until contact, so the lower force limit that keeps the grasp and the upper limit that avoids damage must be found in real time during contact.
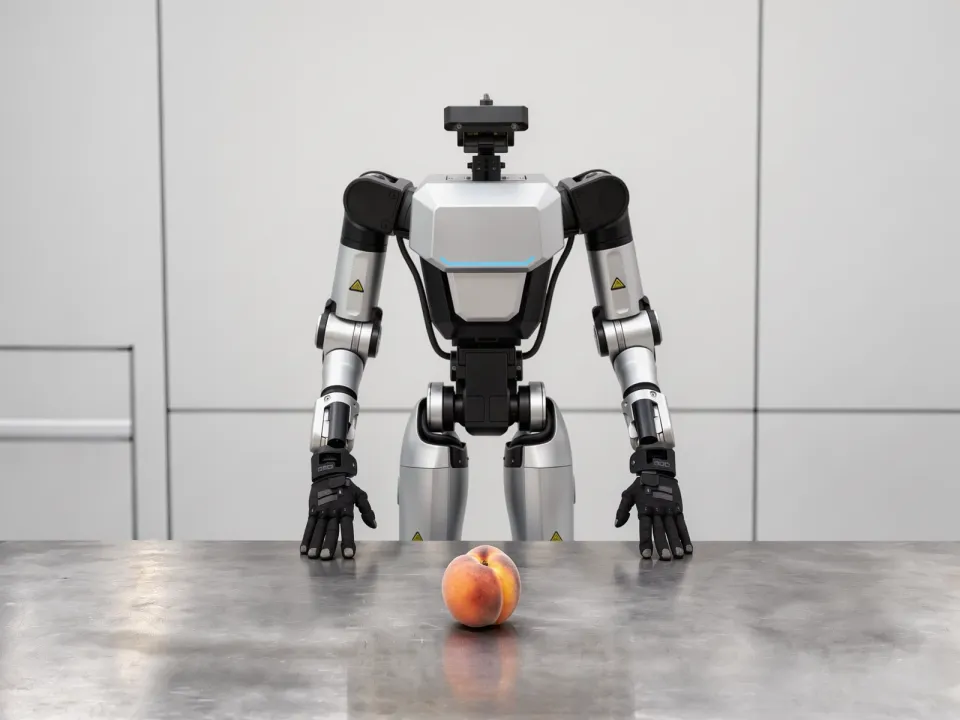
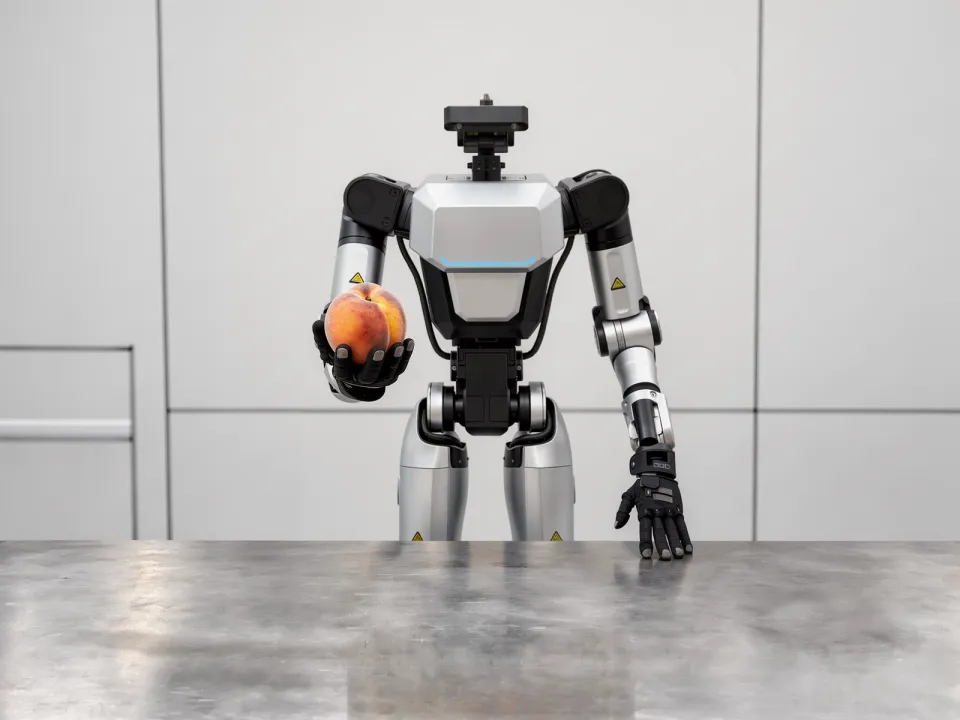
Soft Object Picking — Initial state
Initial stateAn object that pressure would damage rests on a support surface.
Soft Object Picking — Final state
Final stateThe object is grasped without damage.
C_geom does not applyC_force appliesC_contact does not applyC_obs appliesC_deform appliesC_dyn does not apply
E1 does not applyE2 does not applyE3 does not applyE4 appliesE5 does not apply

01-GMoving Object Picking

The object's state at the time of observation differs from its state during motion, so acting on the observed moment leaves the hand already off target at contact.
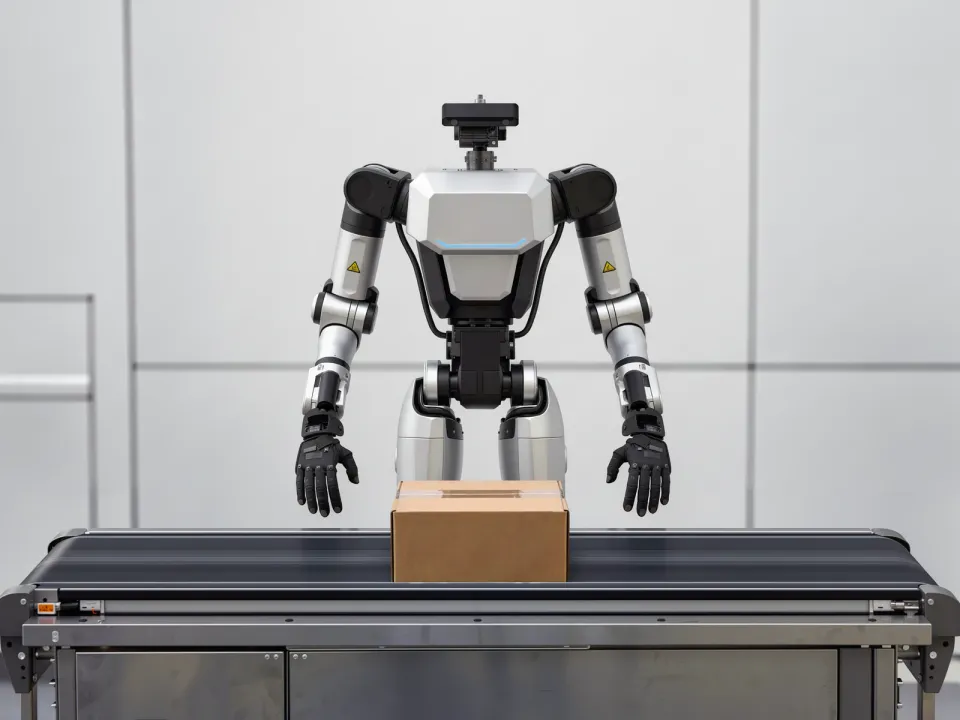
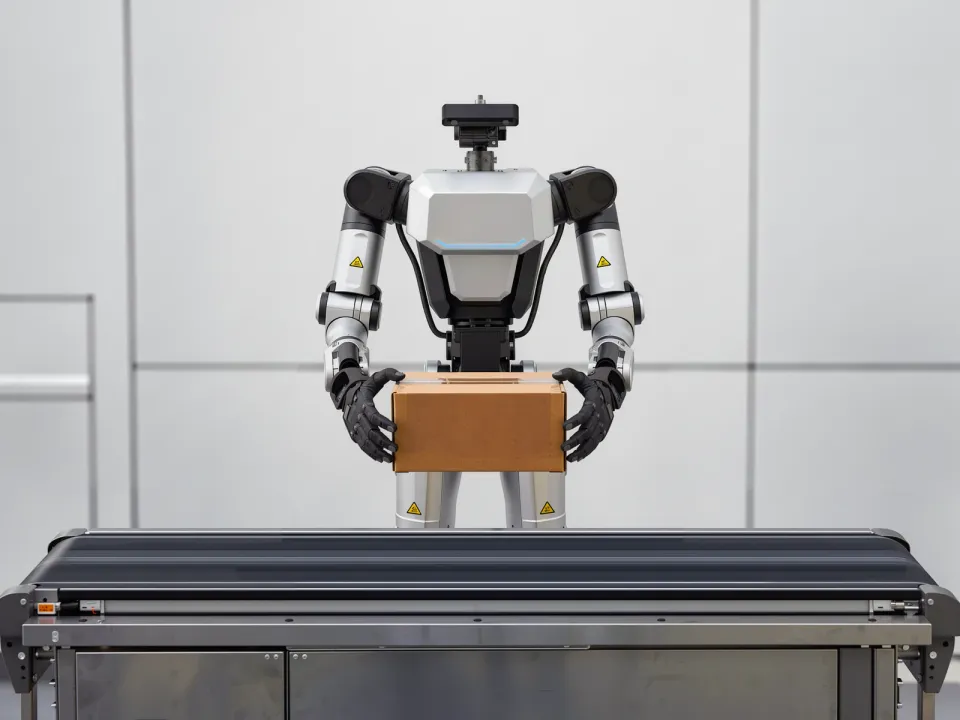
Moving Object Picking — Initial state
Initial stateAn object is moving at a constant speed.
Moving Object Picking — Final state
Final stateThe object that was moving is grasped and removed from its path.
C_geom does not applyC_force does not applyC_contact does not applyC_obs appliesC_deform does not applyC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 does not applyE5 does not apply

01-HOversized Object Picking

The object is too large to grasp with one hand, so several contacts must work together, and the load distribution across them must be maintained throughout the lift.
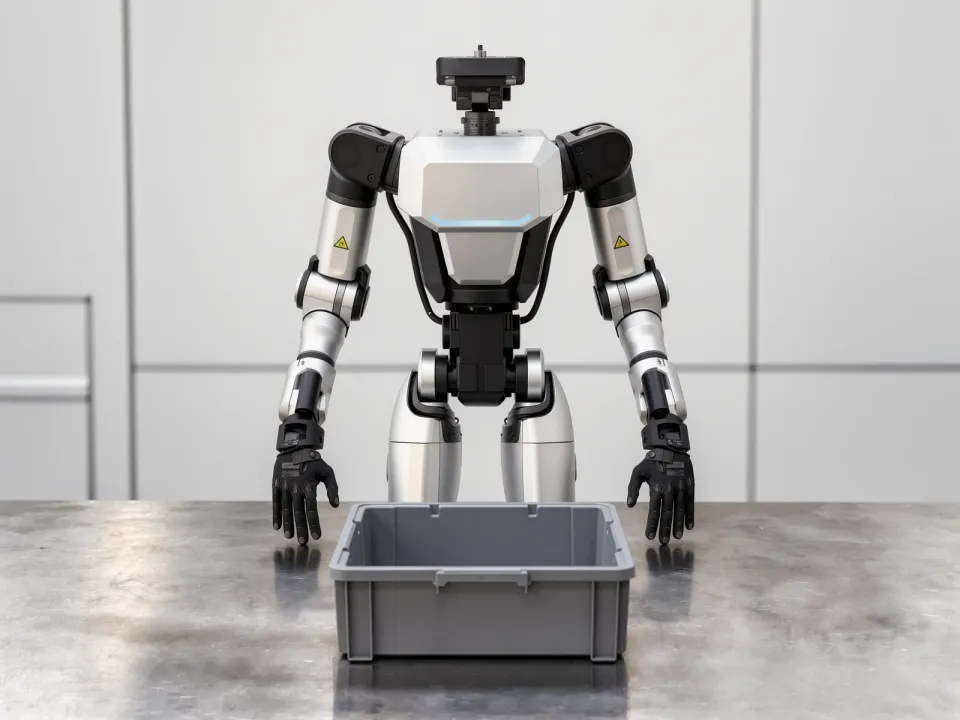
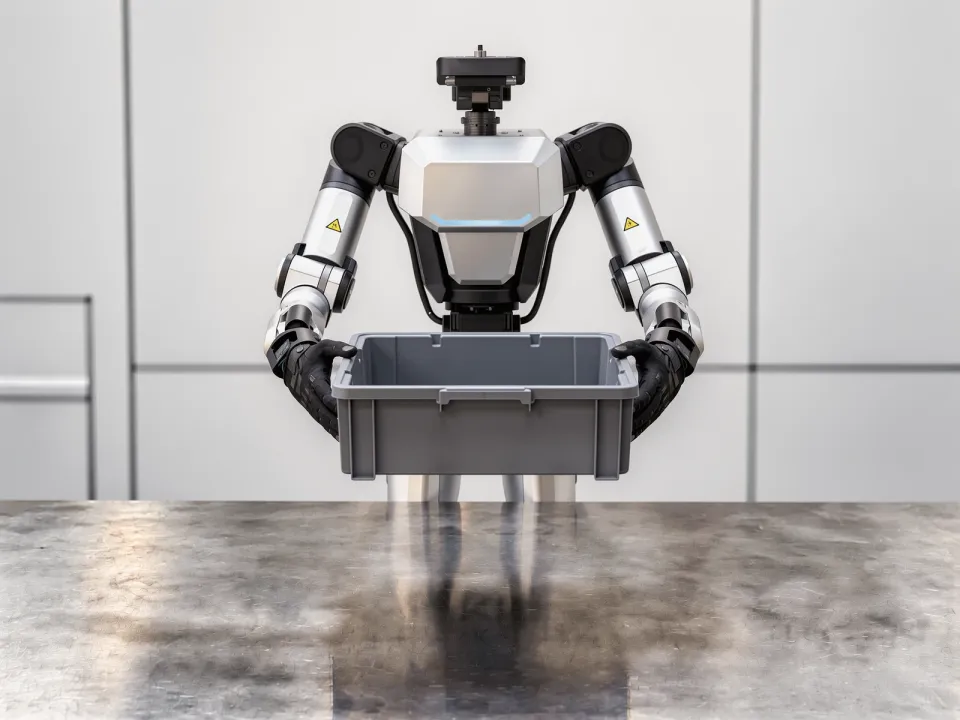
Oversized Object Picking — Initial state
Initial stateAn object too large for a one-hand grasp rests on a support surface.
Oversized Object Picking — Final state
Final stateThe object is supported at several contact points and lifted into the air.
C_geom does not applyC_force appliesC_contact appliesC_obs does not applyC_deform does not applyC_dyn does not apply
E1 appliesE2 does not applyE3 does not applyE4 appliesE5 does not apply

01-IMicro Object PickingTOOL

Smaller than a fingertip, the object must be handled through a tool, which magnifies the hand's error at the tip while failing to transmit the tip's contact back to the hand.
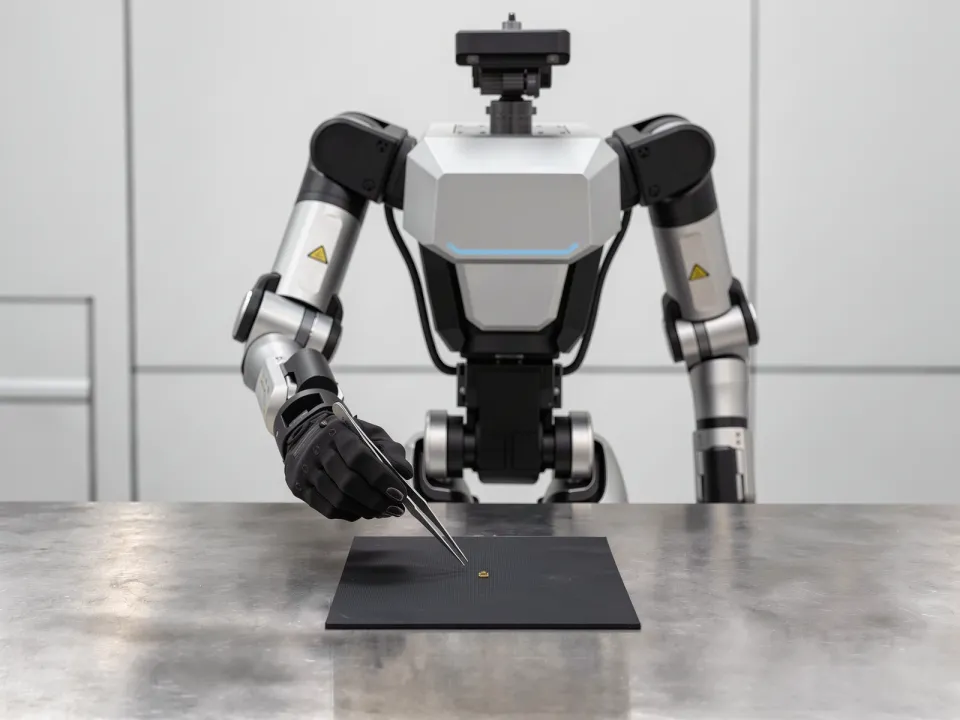
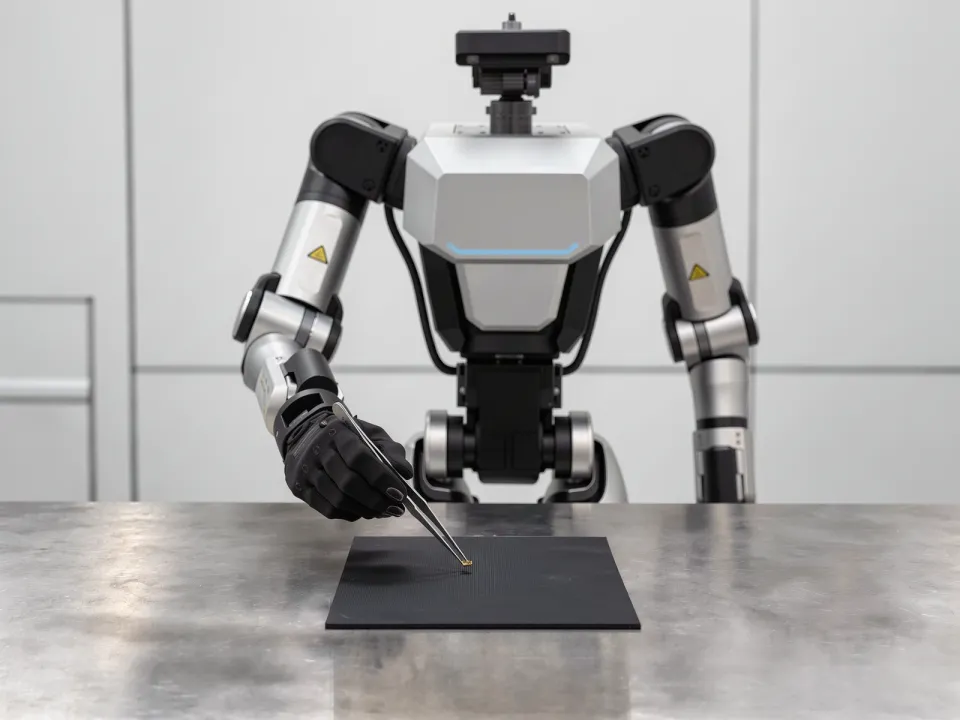
Micro Object Picking — Initial state
Initial stateAn object smaller than a fingertip rests on a support surface, and a tool is held in hand.
Micro Object Picking — Final state
Final stateThe object is grasped by the tool tip and lifted into the air.
C_geom appliesC_force appliesC_contact does not applyC_obs appliesC_deform does not applyC_dyn does not apply
E1 does not applyE2 appliesE3 does not applyE4 appliesE5 does not apply

01-JFlowable Media PickingTOOL

There is no discrete item to grasp, so grasping alone cannot secure the target.
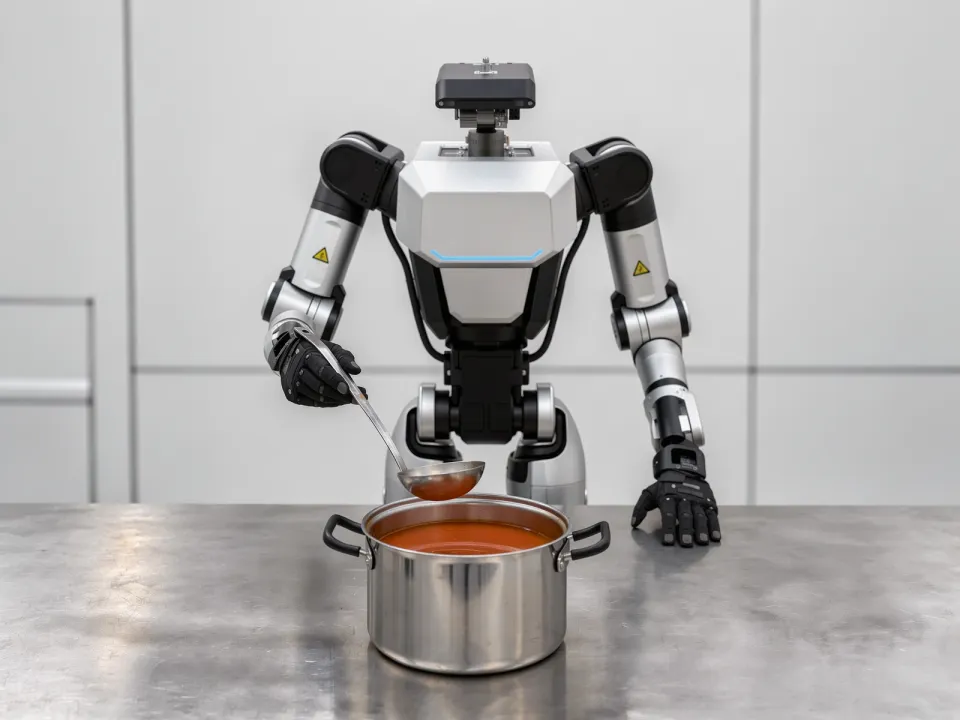
Flowable Media Picking — Initial state
Initial stateAn open container holds flowable media, and a tool is held in hand.
Flowable Media Picking — Final state
Final stateSome of the media are held in the tool and withdrawn from the container.
C_geom appliesC_force does not applyC_contact does not applyC_obs does not applyC_deform appliesC_dyn applies
E1 appliesE2 does not applyE3 does not applyE4 does not applyE5 does not apply