ACTION 04

Placing

Handing an object off from the hand to the environment at a specified pose

Why It Matters

Placing is the moment support passes from the hand to the environment. Examples include inserting items into display slots, setting down fragile cargo, and seating parts on the fixture for the next process.

Dedicated chutes and ejectors suit only objects that can tolerate being dropped. Where both the final pose and clearance from surrounding objects are required, the contact force just before release determines success.

Skills 6

04-ATight-Clearance Placing

The clearance constrains the placement position, approach path and hand shape at once, and the path for withdrawing the hand after release must also fit within the same clearance.
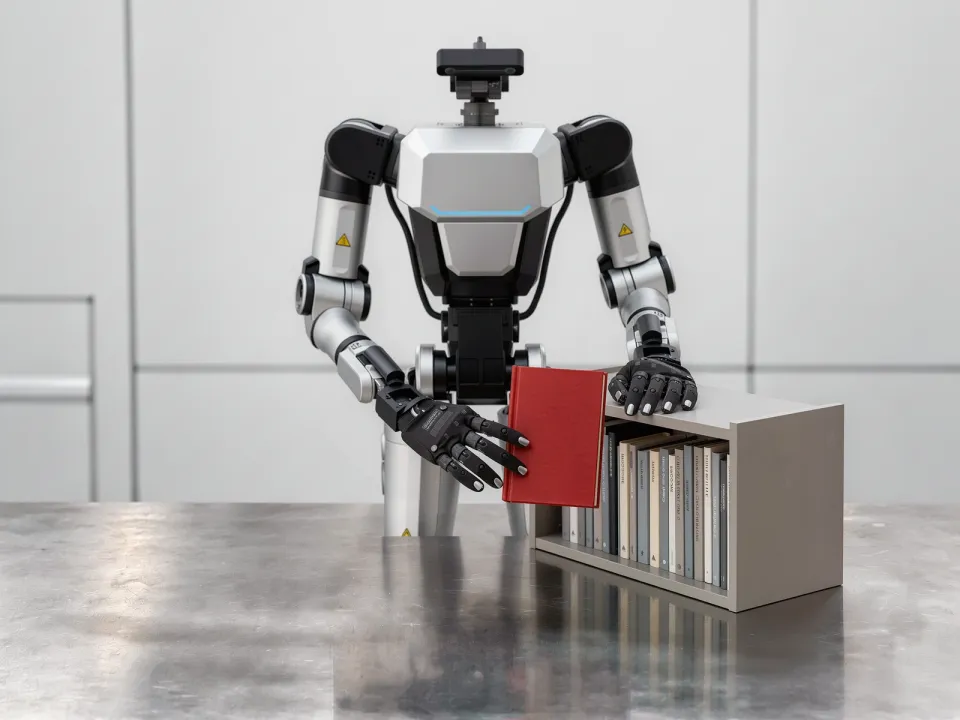
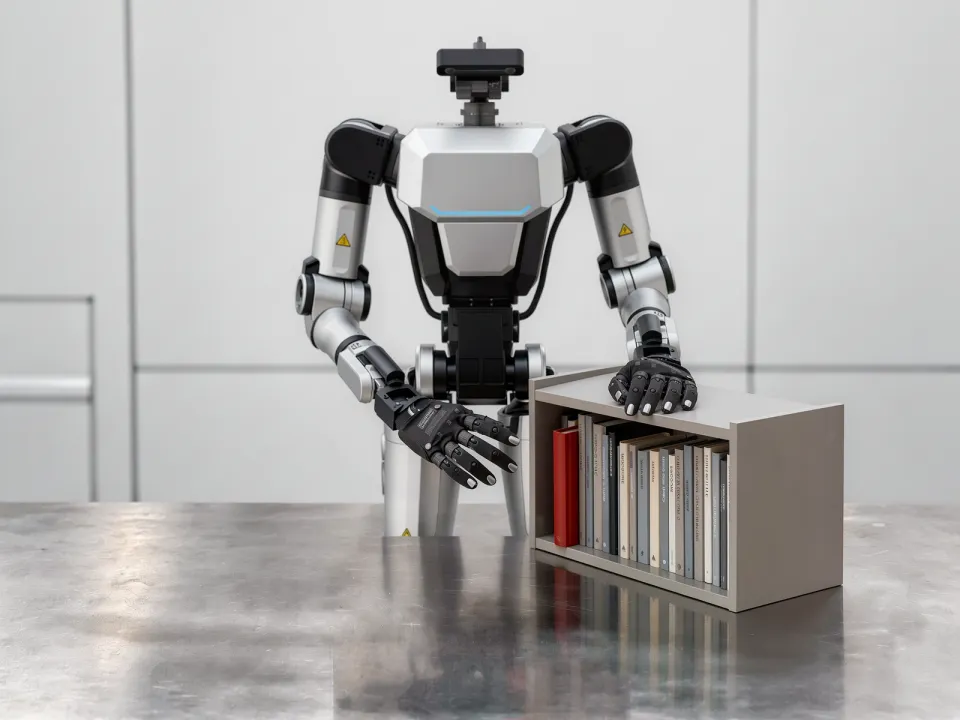
Tight-Clearance Placing — Initial state
Initial stateAn object is held, and there is an open gap almost the same size as the object.
Tight-Clearance Placing — Final state
Final stateThe object is seated in the gap, and the hand has withdrawn.
C_geom appliesC_force does not applyC_contact appliesC_obs appliesC_deform does not applyC_dyn does not apply
E1 appliesE2 appliesE3 does not applyE4 does not applyE5 does not apply

04-BLow-Impact Placing

The impact at contact depends on both the object's stiffness and its remaining momentum, so both must be considered together and the speed adjusted right up to contact.
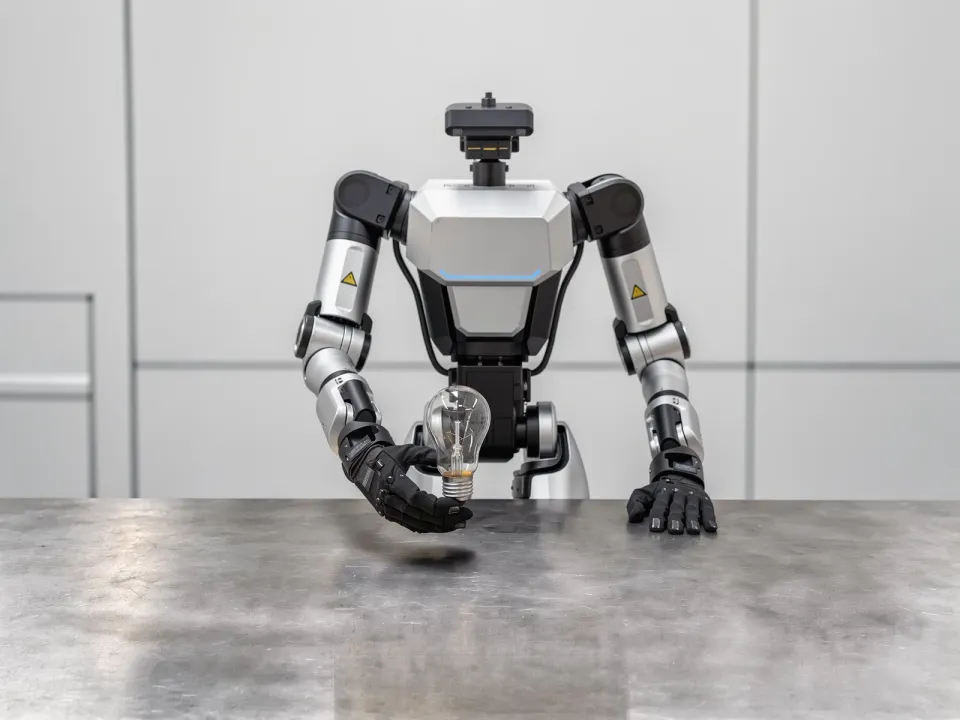
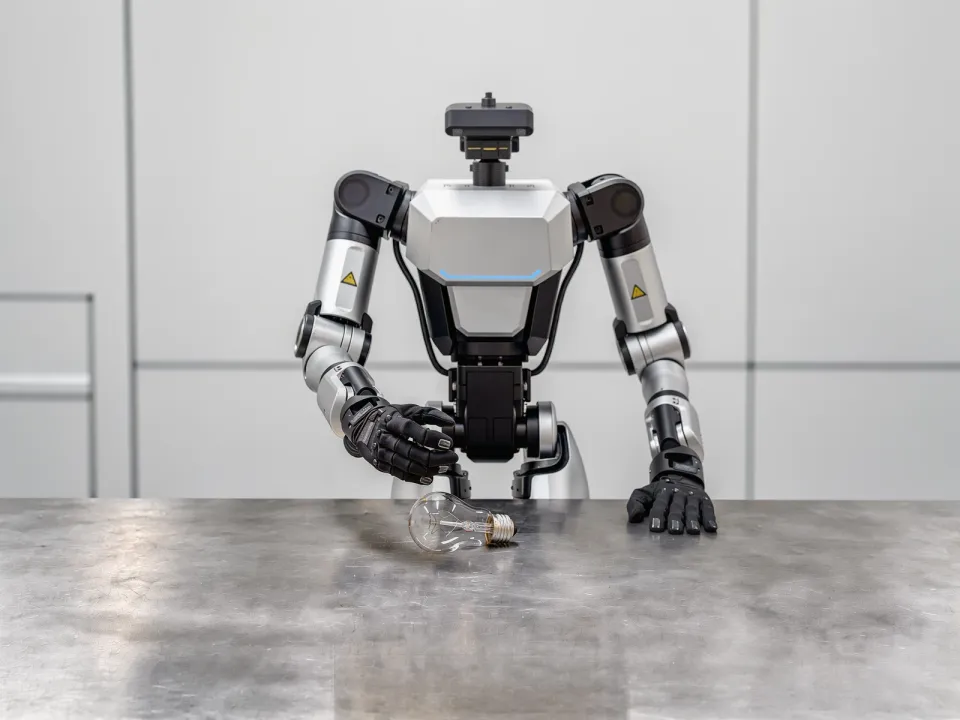
Low-Impact Placing — Initial state
Initial stateAn object that impact would damage is held.
Low-Impact Placing — Final state
Final stateThe object is set down at the target location without damage.
C_geom does not applyC_force appliesC_contact does not applyC_obs does not applyC_deform does not applyC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 appliesE5 does not apply

04-CMoving-Target Placing

The target's state at the time of observation differs from its state during motion, so acting on the observed moment leaves the object already off target at release.
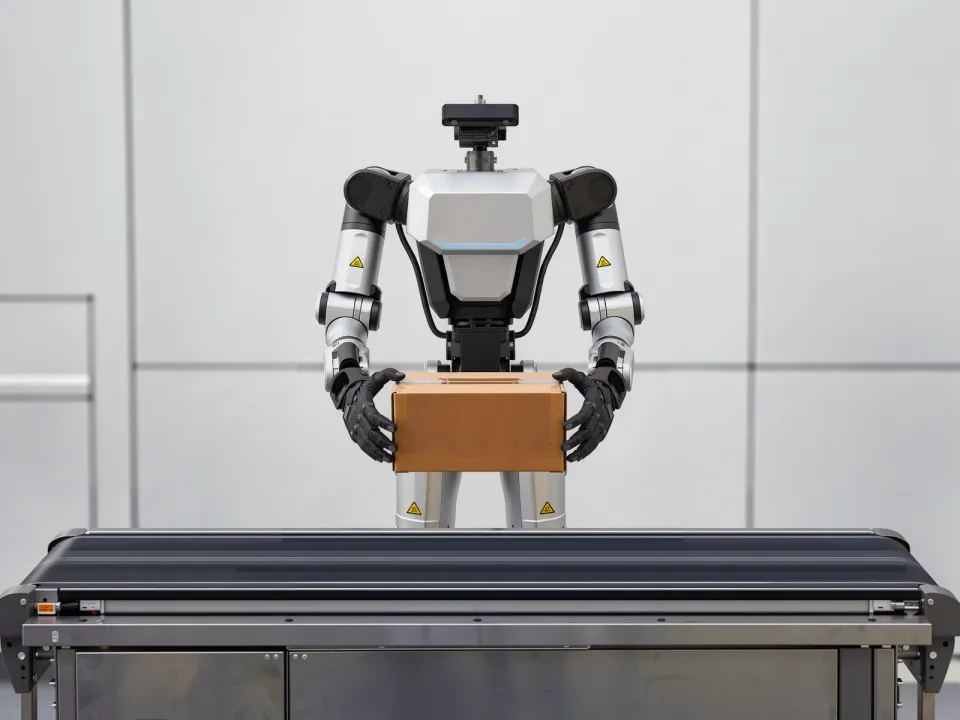
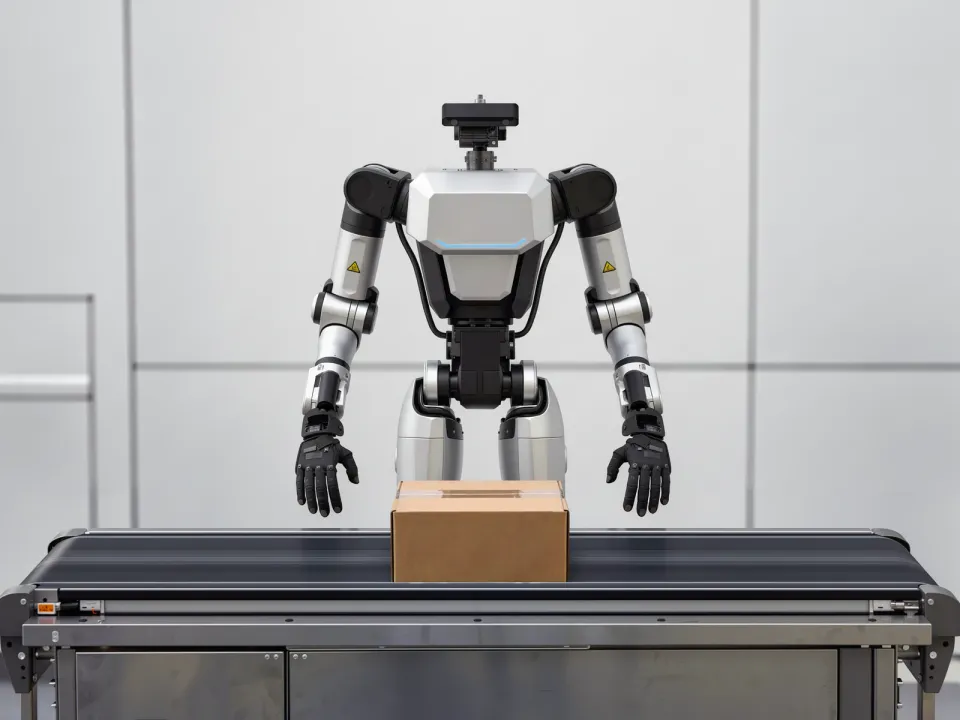
Moving-Target Placing — Initial state
Initial stateAn object is held, and the target point is moving.
Moving-Target Placing — Final state
Final stateThe object is set down on the moving target point.
C_geom does not applyC_force does not applyC_contact does not applyC_obs appliesC_deform does not applyC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 does not applyE5 does not apply

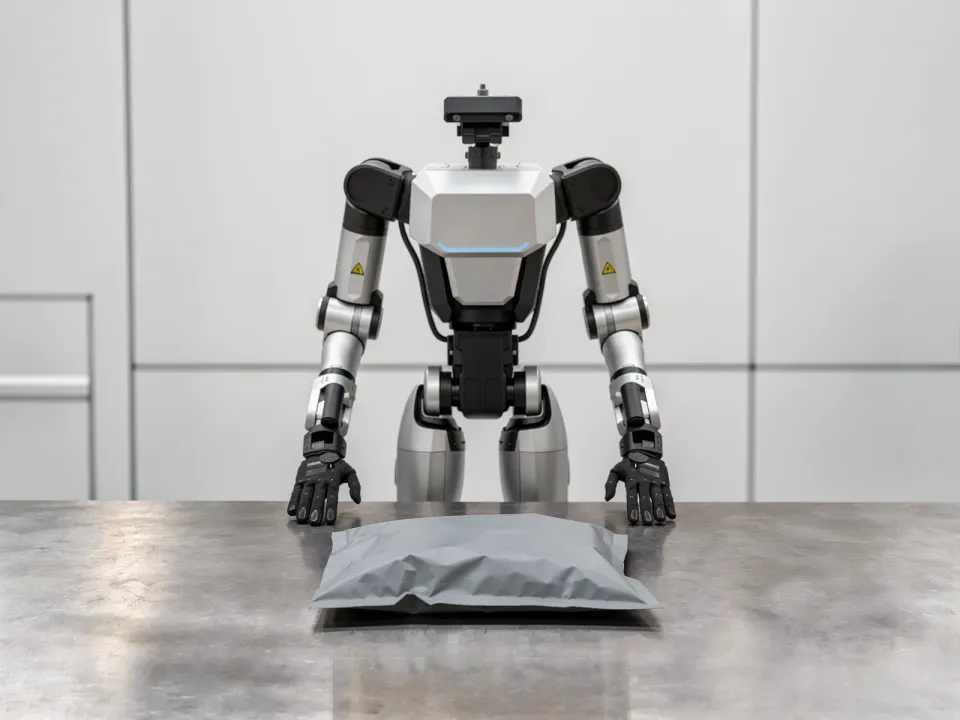
04-DDeformable Object Placing

Once support is withdrawn, the object changes shape under its own weight, so success is judged by the shape it settles into, not the shape held just before release.
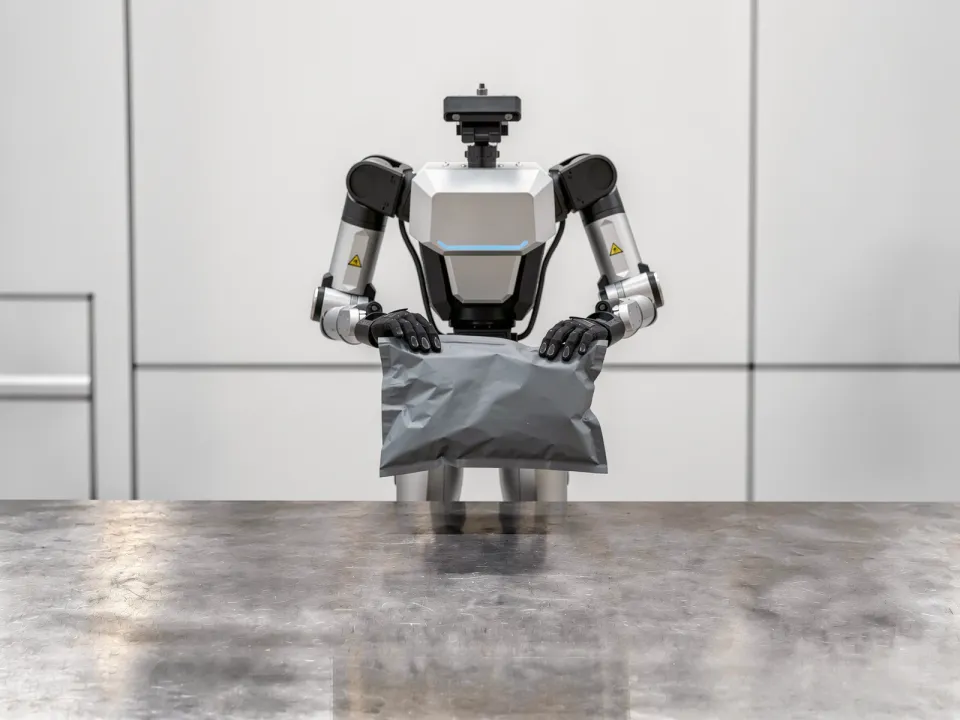
Deformable Object Placing — Initial state
Initial stateA deformable object that must keep its shape is held.
Deformable Object Placing — Final state
Final stateAfter release, the object rests in its target shape.
C_geom does not applyC_force does not applyC_contact does not applyC_obs does not applyC_deform appliesC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 does not applyE5 does not apply

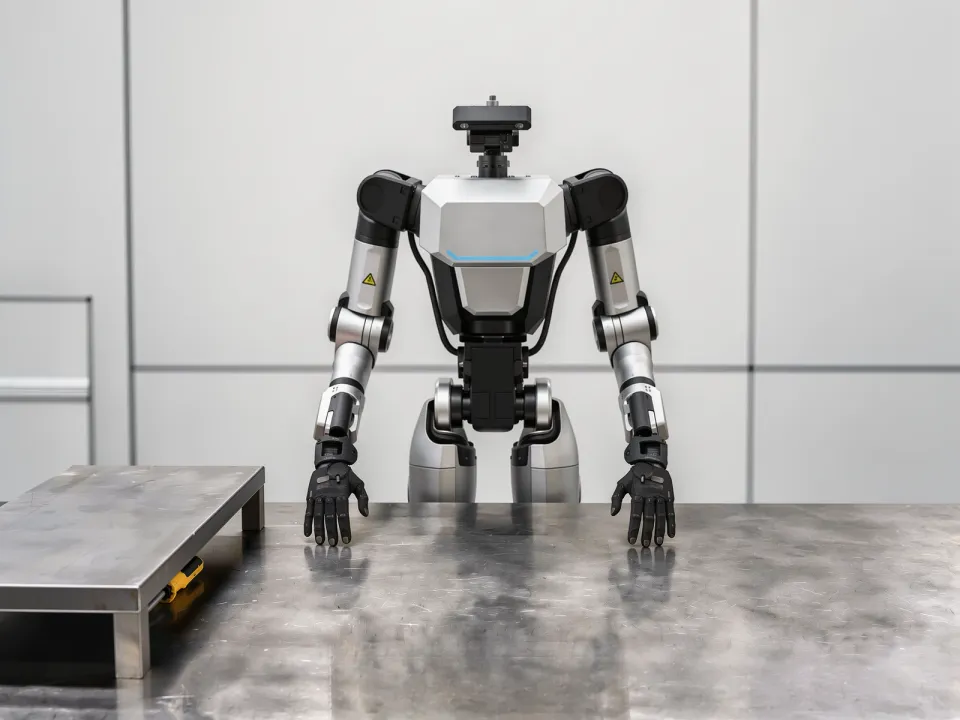
04-EOccluded Placing

The receiving surface cannot be observed, so progress cannot be checked during placement, and success cannot be confirmed afterward.
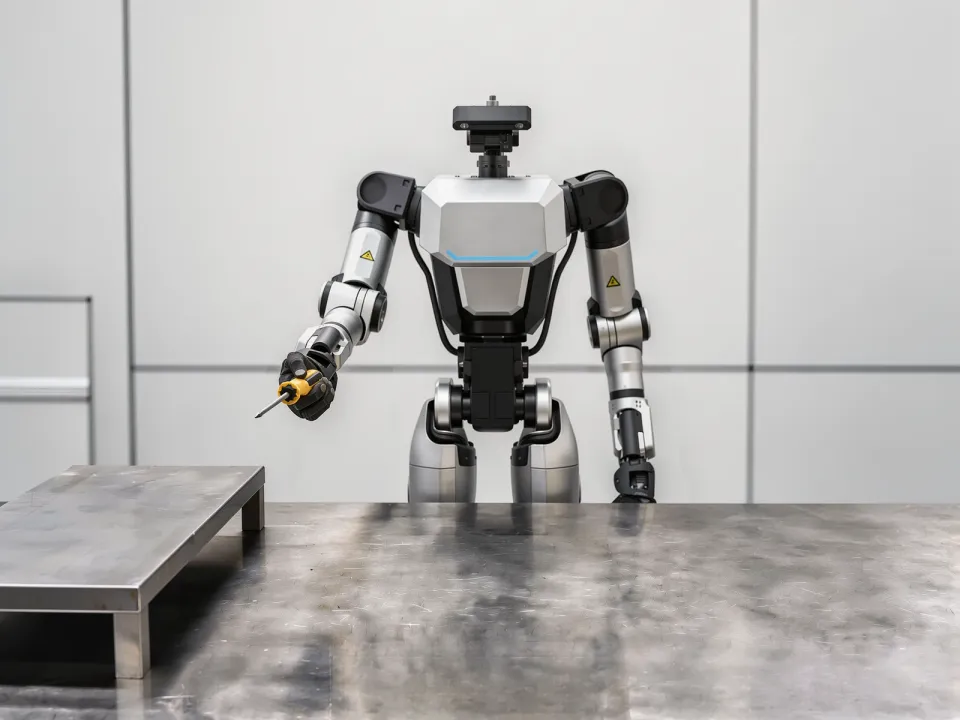
Occluded Placing — Initial state
Initial stateAn object is held, and the target surface cannot be observed.
Occluded Placing — Final state
Final stateThe object is set down on the target surface.
C_geom does not applyC_force does not applyC_contact appliesC_obs appliesC_deform does not applyC_dyn does not apply
E1 does not applyE2 does not applyE3 does not applyE4 appliesE5 does not apply

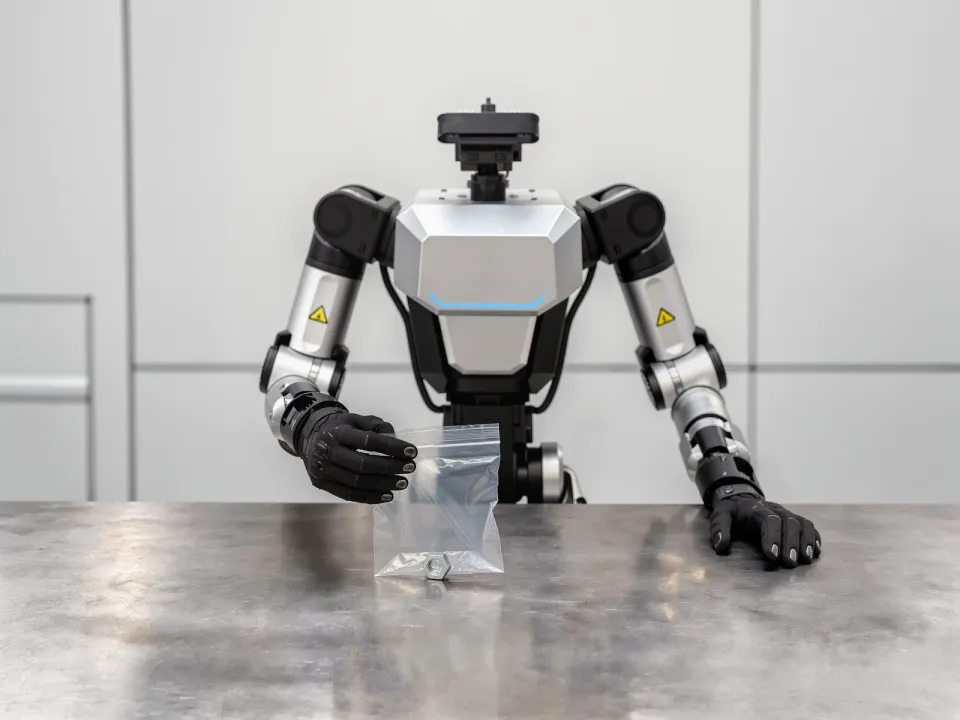
04-FCompliant-Container Placing

The receptacle is not rigid and deforms as soon as the object touches it, so the space being filled changes during insertion.
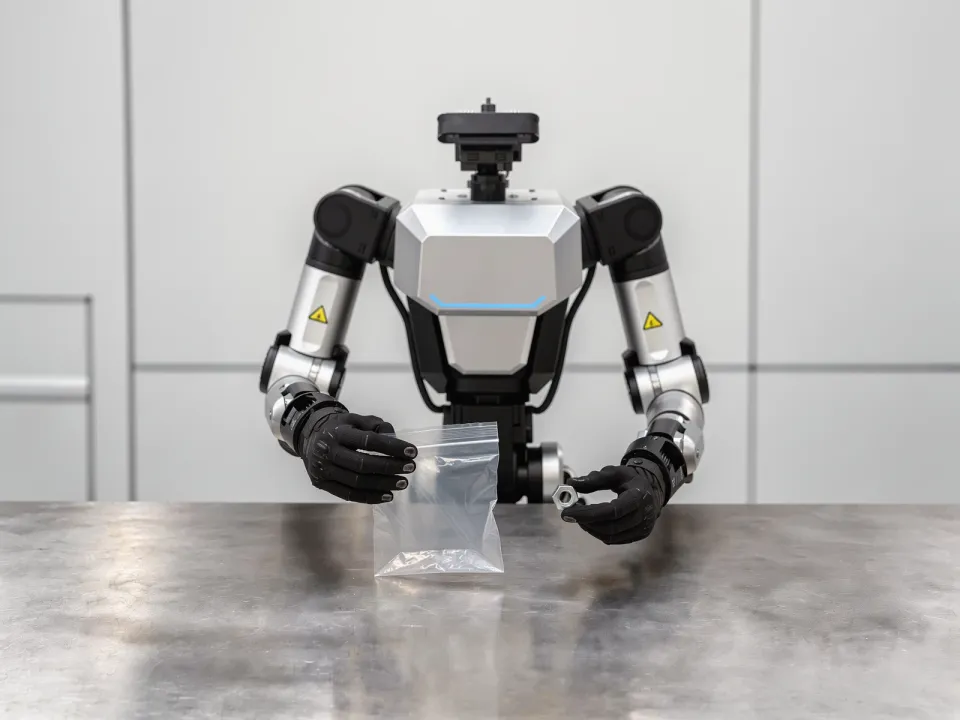
Compliant-Container Placing — Initial state
Initial stateAn object is held, and a flexible receptacle is closed.
Compliant-Container Placing — Final state
Final stateThe object is placed inside the receptacle.
C_geom does not applyC_force appliesC_contact appliesC_obs does not applyC_deform appliesC_dyn does not apply
E1 appliesE2 does not applyE3 does not applyE4 appliesE5 does not apply