ACTION 03

Transporting

Moving a held object so that its state on arrival is identical to its state at departure

Why It Matters

Transporting is often treated as a mere gap between grasping and placing, yet if the object's state is compromised in transit, both the preceding and following steps are invalidated. Examples include serving drinks, carrying parcels that sag significantly, and moving painted parts between stations.

Conveyors and AGVs cover only the stretches where the object is rigid and its pose is fixed. For liquids, deformable items, and large objects that one hand cannot secure, transport itself changes their state.

Skills 5

03-ADeformable Object Transport

The hand's motion does not carry through the whole object, so its parts move independently, and its shape and path in transit cannot be predicted.
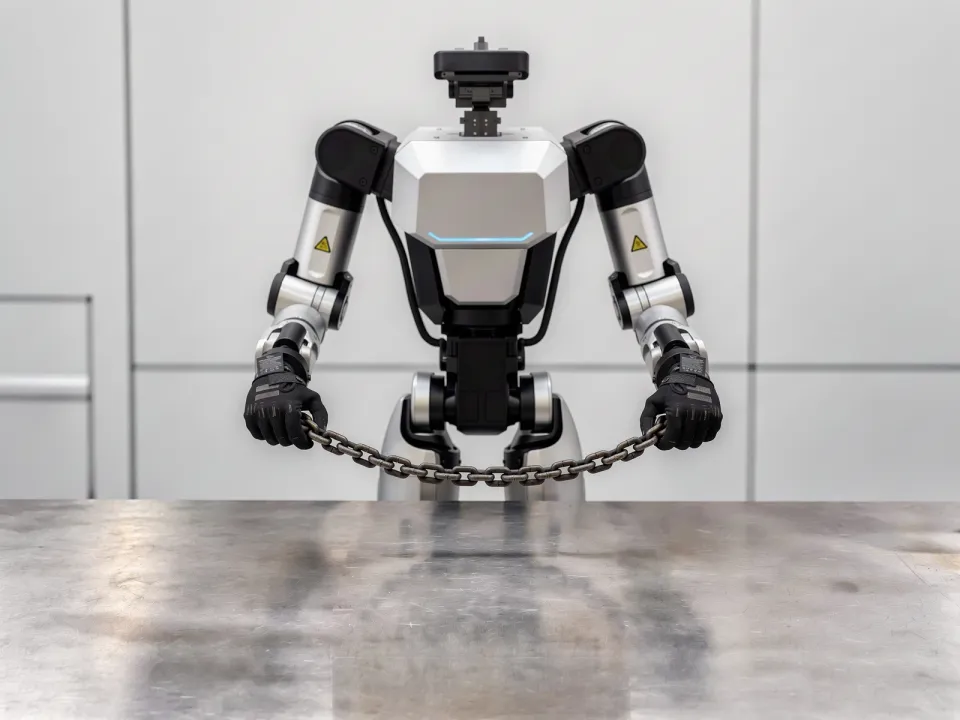
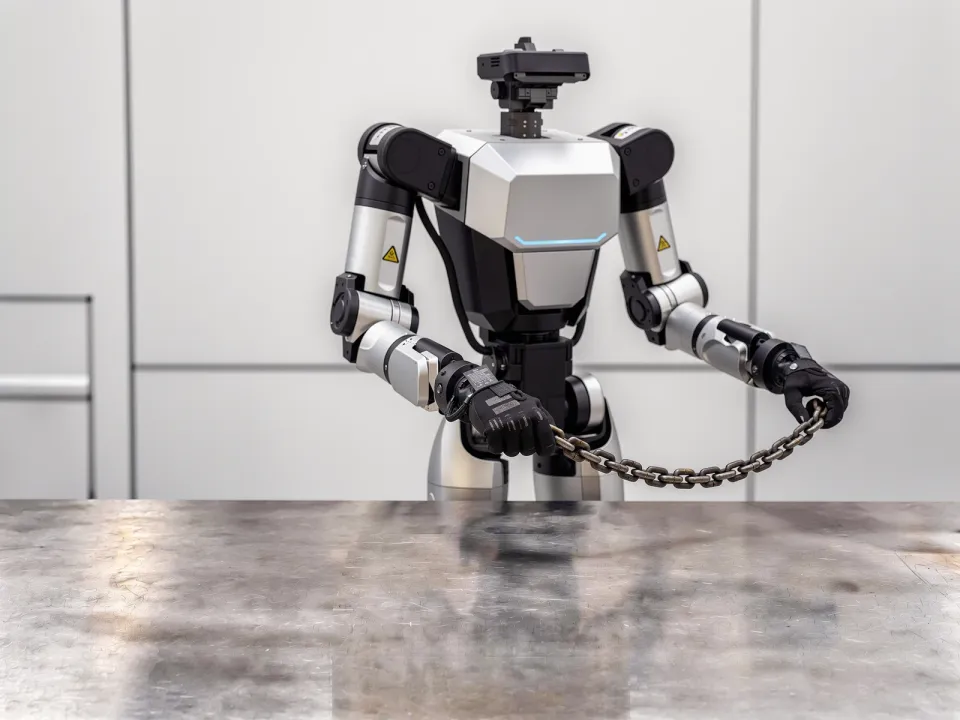
Deformable Object Transport — Initial state
Initial stateAn object that changes shape under its own weight is held.
Deformable Object Transport — Final state
Final stateThe object is moved to the target location with its shape intact.
C_geom does not applyC_force does not applyC_contact does not applyC_obs does not applyC_deform appliesC_dyn applies
E1 appliesE2 does not applyE3 appliesE4 does not applyE5 does not apply

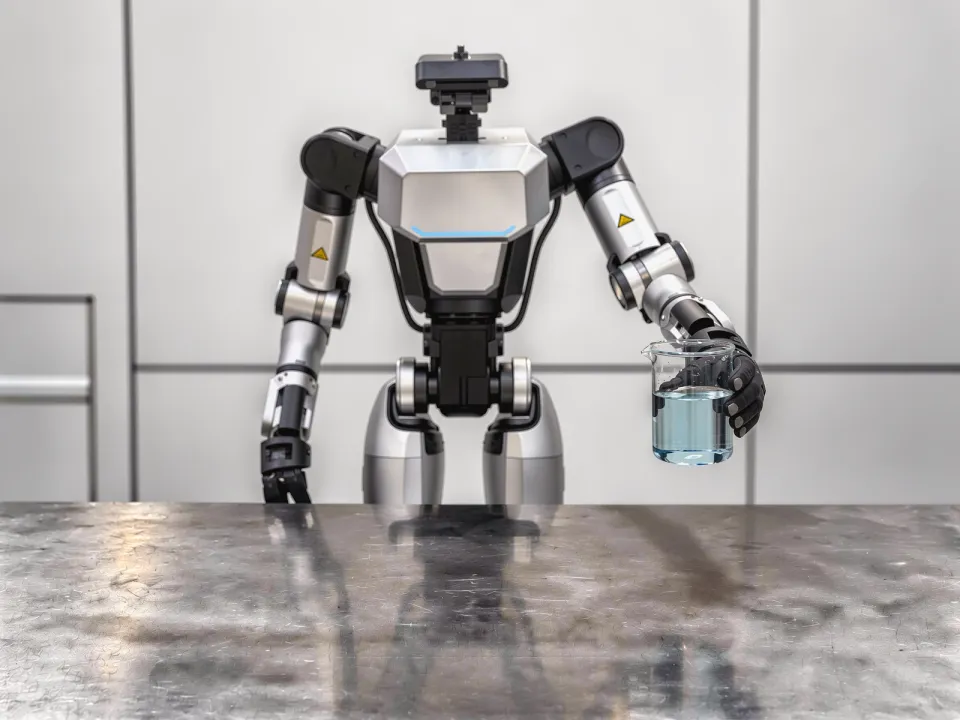
03-BFlowable Media Transport

The contents move independently of the container, building up momentum with every acceleration and deceleration, and that motion persists after the container stops, so the contents' state is not preserved.
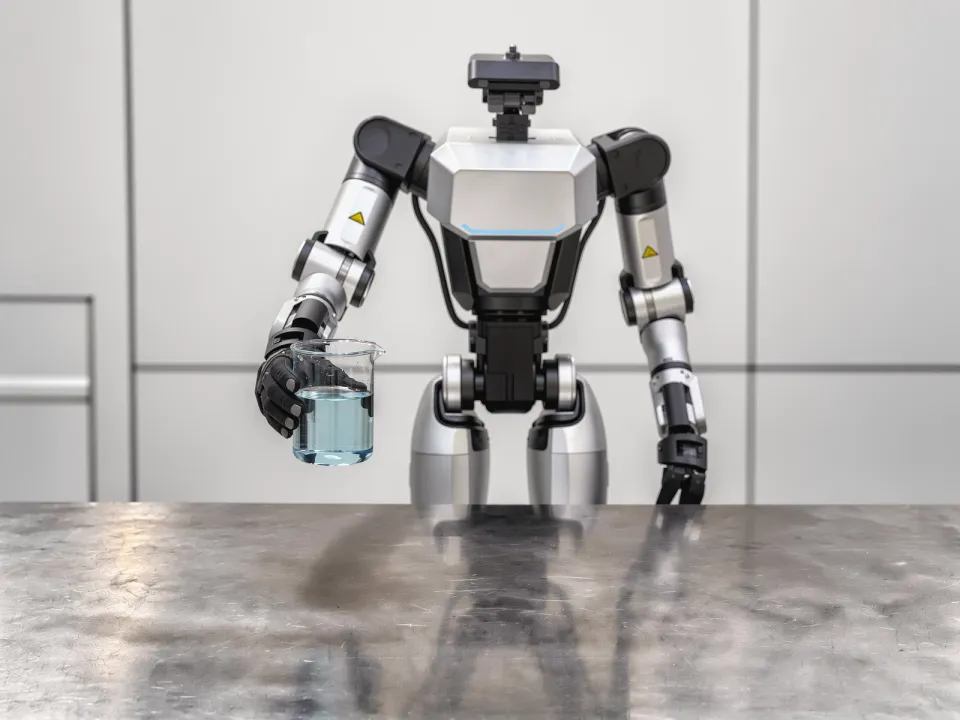
Flowable Media Transport — Initial state
Initial stateA container holding flowable media with a free surface is held.
Flowable Media Transport — Final state
Final stateThe container is moved to the target location without spilling.
C_geom does not applyC_force does not applyC_contact does not applyC_obs does not applyC_deform appliesC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 does not applyE5 does not apply

03-COversized Object Transport

The object is too large to grasp with one hand, so it must be carried on several contacts whose balance must be maintained throughout the move.
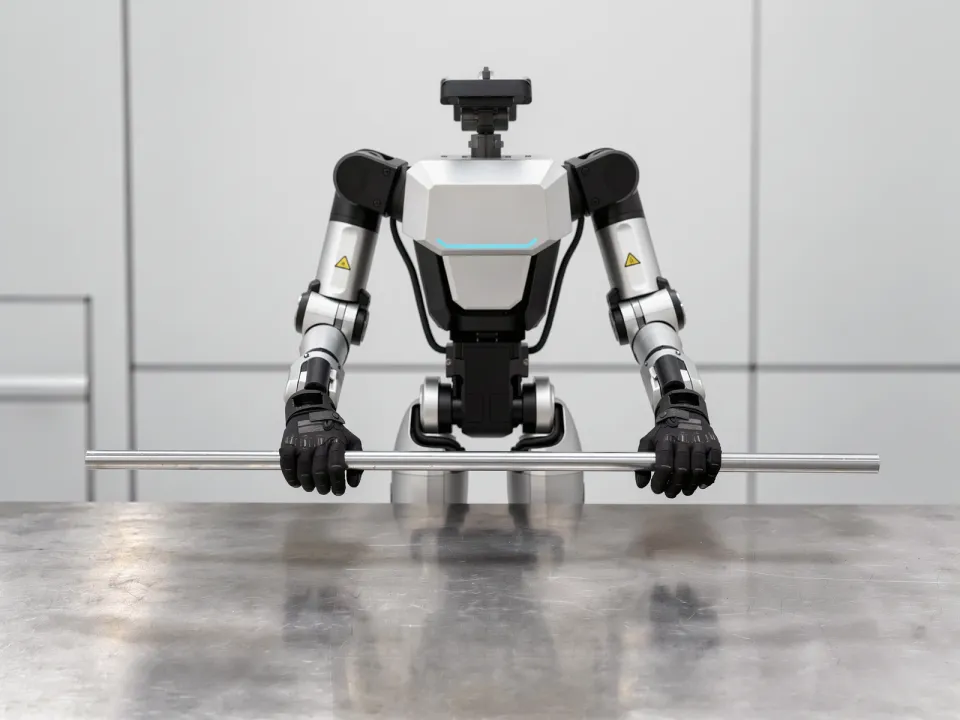
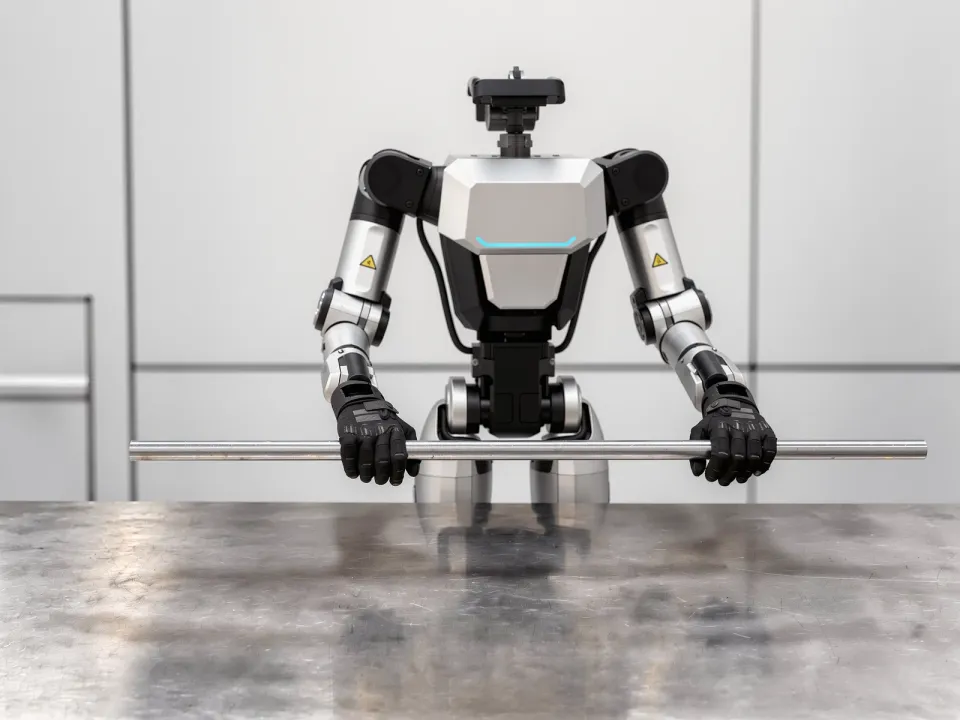
Oversized Object Transport — Initial state
Initial stateA large object supported at several contact points is at its starting location.
Oversized Object Transport — Final state
Final stateThe object is moved to the target location with its support maintained.
C_geom does not applyC_force appliesC_contact appliesC_obs does not applyC_deform does not applyC_dyn applies
E1 appliesE2 does not applyE3 does not applyE4 appliesE5 does not apply

03-DUnknown-Load Transport

Unseen contents shift inside, so the center of mass becomes known only after lifting and keeps changing in transit.
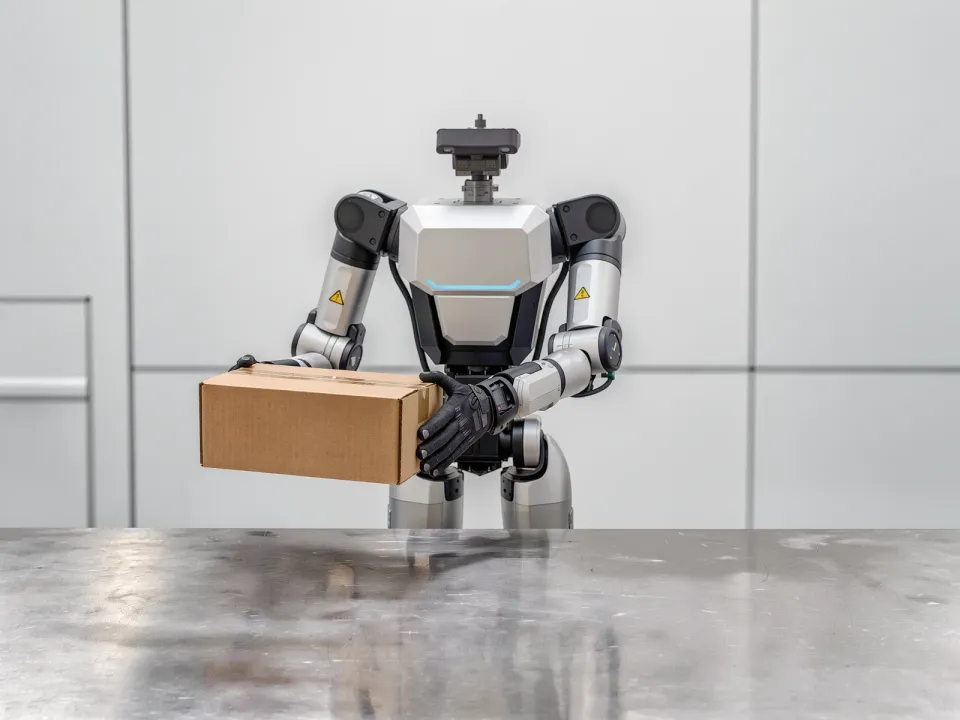
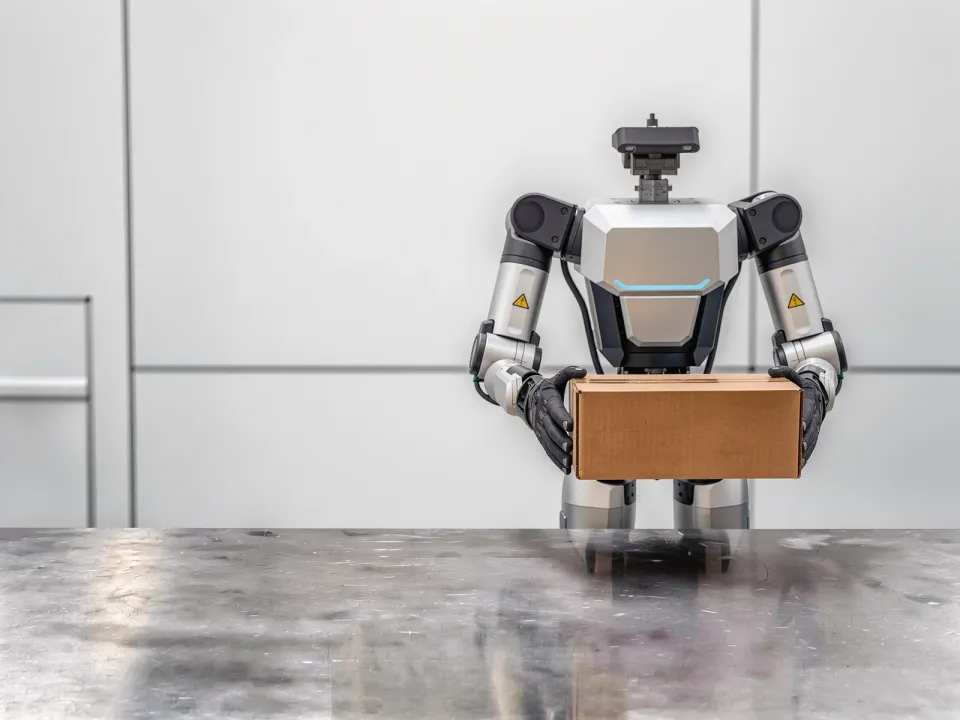
Unknown-Load Transport — Initial state
Initial stateAn object whose weight and center of mass are unknown is held.
Unknown-Load Transport — Final state
Final stateThe object is moved to the target location with its pose maintained.
C_geom does not applyC_force appliesC_contact does not applyC_obs appliesC_deform does not applyC_dyn applies
E1 does not applyE2 does not applyE3 appliesE4 appliesE5 does not apply

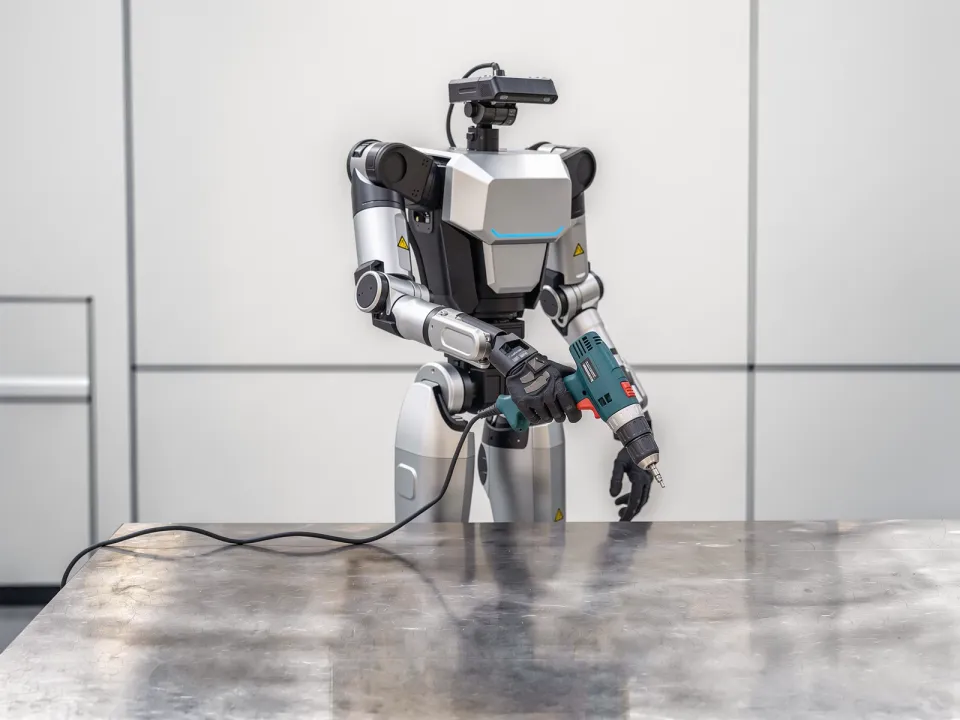
03-ETethered Object Transport

A line attached to the object stays in contact with the surroundings, so whenever it drags or snags, the pull changes the object's pose regardless of the hand.
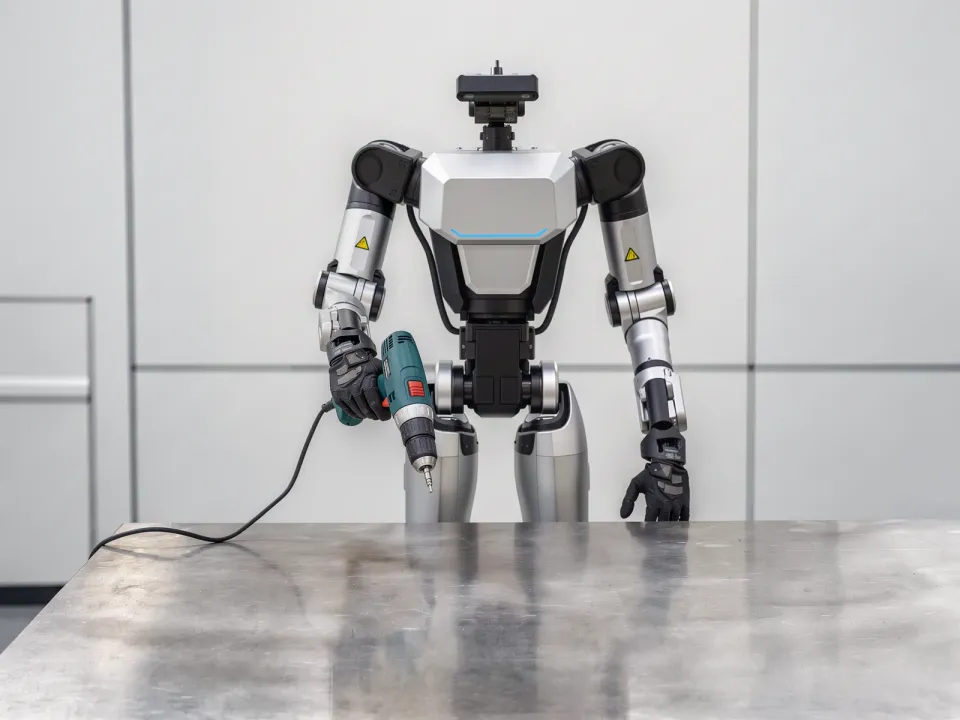
Tethered Object Transport — Initial state
Initial stateAn object tethered to its surroundings by a line is held.
Tethered Object Transport — Final state
Final stateThe object is moved to the target location without interference from the line.
C_geom does not applyC_force does not applyC_contact appliesC_obs does not applyC_deform appliesC_dyn does not apply
E1 does not applyE2 does not applyE3 does not applyE4 appliesE5 applies